- Gifts & Party Decorations
- Phone Accessories
- Photo & Video
- Computers & Electronics
- Sports & Fitness
- Beauty & Health
- Car & Motorcycle Accessories
- Bicycle Accessories
- Home & Living
- Garden & Outdoor
- Baby & Kids Products
- Games, Hobbies & Leisure
- Travel & Outdoor Activities
- Pet Supplies
- Discounted Items & Products with Defects
Robotic Hands UNITREE G1 Dex3-1 L+R DX31-214N
Unitree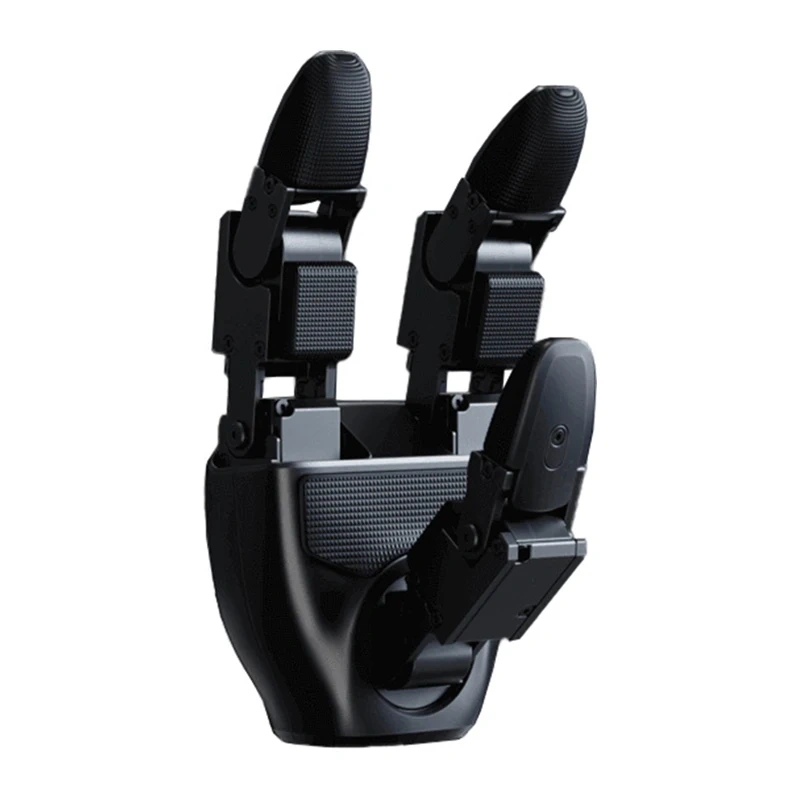
| Products ID: | 195430 |
|---|---|
| Manufactured by: | Unitree |
| Availablity: | Ready to Order |
| Delivery Time | 5-12 business days |
| EAN: | 5905156112056 |
Delivery options to:
Choose countryThe UNITREE G1 Dex3-1 set includes a left and right three-fingered robotic hand designed to work with the UNITREE G1 humanoid robot. Each hand provides 7 degrees of freedom and utilizes 7 miniature brushless joints with force control.
Precise Movement and Joint Articulation
Each Dex3-1 hand features three articulated fingers: the thumb has 3 degrees of freedom, the index finger has 2, and the middle finger has 2. The extensive range of motion of each joint supports complex grasping postures across multiple planes, while fingertip positioning repeatability of ±2 mm ensures reliable, repeatable motions.
Hybrid Force Control and Motor Drives
UNITREE Dex3-1 applies hybrid force and position control for versatile operational dynamics. The mechanical design of each hand integrates 6 direct-drive brushless motors and 1 geared motor using F-1515-108 and F-1515-214 joint modules, enabling precise control of torque, angle, angular velocity, stiffness, and damping.
High-Frequency Communication and Feedback
Operating via a USB 2.0 interface with a communication frequency of 1000 Hz, the system provides real-time telemetry. Sensing feedback covers joint mode, position, velocity, torque, temperature, voltage, current, and IMU data, while internal joint communication runs over High Speed Unibus.
| Manufacturer | UNITREE |
|---|---|
| Model | DX31-214N |
| Compatibility | UNITREE G1 |
| Weight | 710 g |
| Dimensions | 175 × 88 × 77 mm (when extended) |
| Degrees of Freedom | Thumb ×3, Index finger ×2, Middle finger ×2 |
| Drive Mechanism | 6 direct-drive motors, 1 gear-driven motor |
| Joint Range of Motion | Thumb joint 0: -60° to 60°; Thumb joint 1: -35° to 60°; Thumb joint 2: 0° to 100°; Index finger joint 0: 0° to 90°; Index finger joint 1: 0° to 100°; Middle finger joint 0: 0° to 90°; Middle finger joint 1: 0° to 100° |
| Fingertip positioning repeatability | ±2 mm |
| Operating voltage | 12–58 V |
| Quiescent current | 0.2 A at 58 V |
| Maximum current | 10 A |
| Communication interface | USB 2.0 |
| Operating temperature range | From -20°C to 60°C |
| Load conditions (palm facing down) | Maximum weight: 500 g; Maximum power: 400 W for 3 s |
| Load conditions (palm facing left) | Maximum weight: 500 g; Maximum power: 400 W for 3 s |
| Communication frequency | 1000 Hz |
| Data packet size | Transmitter: 1234 bytes; Receiver: 1270 bytes |
| Measurement feedback data | Joint mode, position, speed, torque, temperature, voltage, current, IMU data |
| Control feedback data | Joint mode, position, speed, torque, stiffness coefficient, damping coefficient |
| Joint models | F-1515-108, F-1515-214 |
| Joint weight | 45 g |
| Joint dimensions | 34.8 × 23.1 × 23.3 mm |
| Gear Ratio | F-1515-108: 1:108; F-1515-214: 1:214 |
| Maximum torque (theoretical) | F-1515-108: 0.76 Nm; F-1515-214: 1.498 Nm |
| Actual torque (rotation direction) | F-1515-108: 0.49 Nm; F-1515-214: 0.86 Nm |
| Actual torque (opposite direction) | F-1515-108: 1.37 Nm; F-1515-214: 3.1 Nm |
| Maximum rotational speed | F-1515-108: 23 rad/s; F-1515-214: 11 rad/s |
| Maximum line current | 4.76 A |
| Joint control frequency | 1000 Hz |
| Joint communication method | High Speed Unibus |
| Encoder | Absolute rotor position encoder |
| Joint operating voltage | 12–24 V |
Which robot are the Dex3-1 robotic hands compatible with?
The UNITREE Dex3-1 robotic hands are specifically designed for the UNITREE G1 humanoid robot.
Do these hands include tactile sensors?
No, this version of the UNITREE G1 Dex3-1 hands comes without tactile sensors.
What is the fingertip positioning repeatability?
The positioning repeatability of the fingertip is ±2 mm.